 Login


Eye-Catching:
Stand out at trade shows, classrooms, everywhere.

Sleek Design:
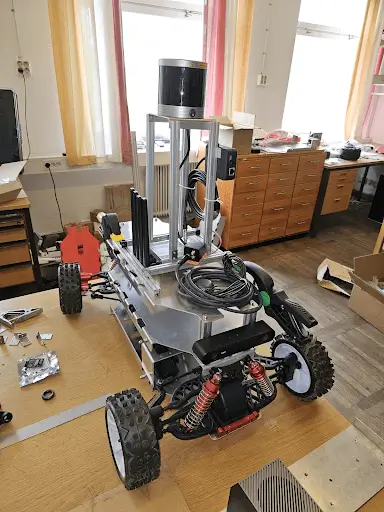
A 1:5 scale, 10kg marvel that captivates with its fierce look.

Flexibility:
Easily mount your hardware for a tailored experience.

CAN Bus Integration:
Show your products in action with our CAN & electronics kit.

For Corporations:
Elevate presentations, forge connections and showcase products.

For Educators:
Hands-on learning, bridging theory and practice.

Open Source:
Reference applications built on open-source software available.

Advanced Control System
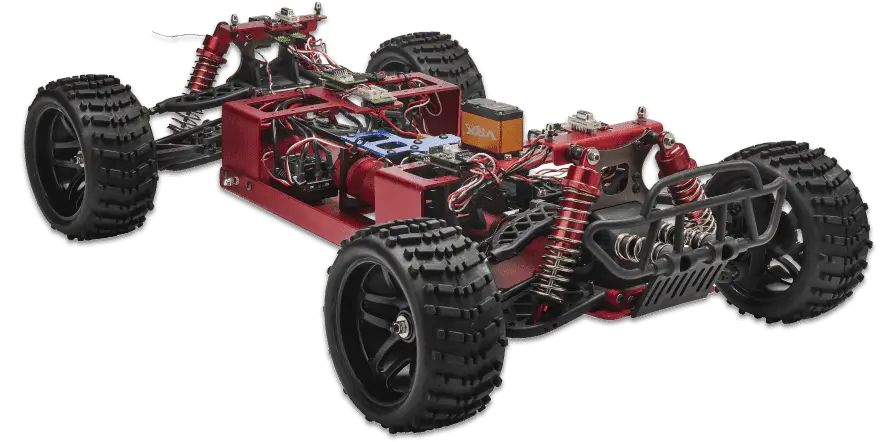
Equipped with a CAN system featuring three nodes—a motor control node, steering node and radio communication node.

Connectivity Made Easy
The CAN bus is designed with four 9-pin D-SUB connectors, ensuring hassle-free connections to PCs and additional modules.

Modular Design
The car's bodywork boasts easily detachable aluminum mounting panels, allowing for seamless integration of additional modules.

Standard RC with a Twist
CanEduDev introduces a revolutionary RC-to-CAN control module, enabling the Demo Rover to be seamlessly controlled by any RC system.

Robust Carrying Case
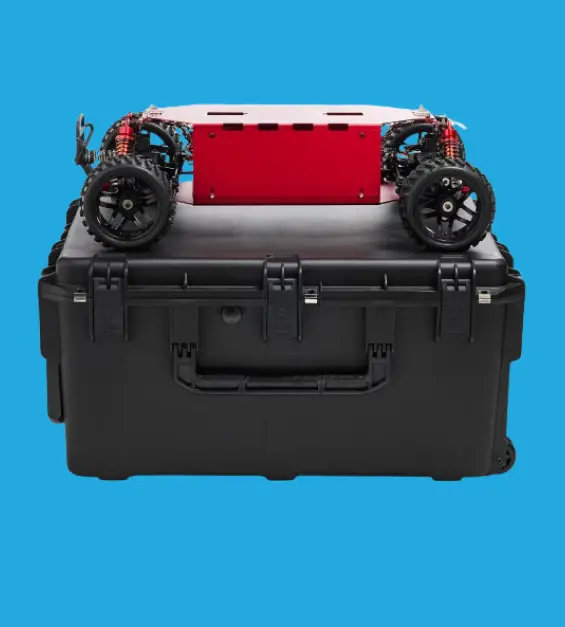
Transport your Demo Rover with style and security. We've collaborated with SKB to craft a bespoke carrying case tailored for the Demo Rover.

Open Source
The Demo Rover’s schematics and software are open source and freely available. The firmware is built on the open-source STM32 HAL and FreeRTOS.
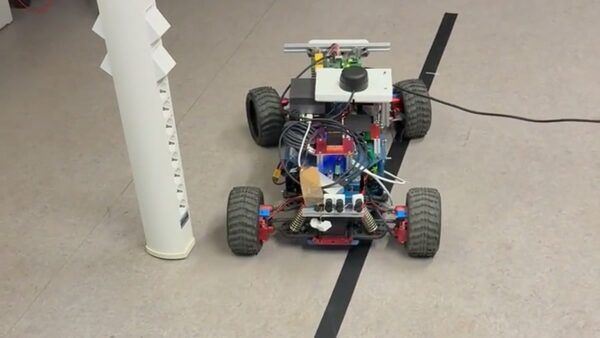
From “find a chair” to the CAN bus: KTH students teach the Rover to navigate by language
Halfway through their DD2414 project, three students have built a complete real-world navigation stack on the CanEduDev Rover. Next, they’ll tell it where to go in plain English. Ask a robot to “find a chair”
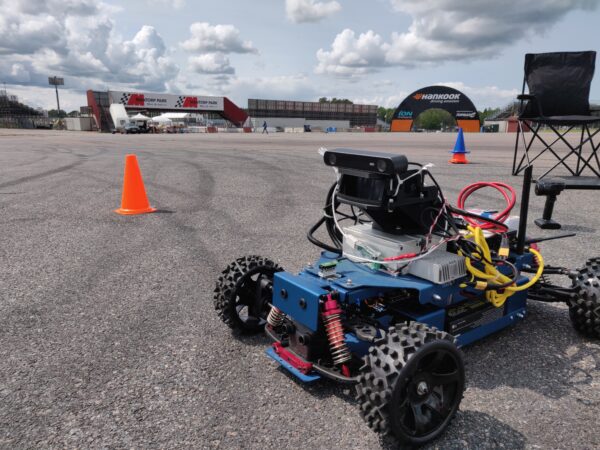
From Simulation to Skidpad: How the CanEduDev Rover is Accelerating LiU Formula Student’s Driverless Ambitions
For any team in the high-stakes world of autonomous racing, the gap between a promising algorithm in a simulator and a car executing a flawless run on the track is immense. It’s a gap filled
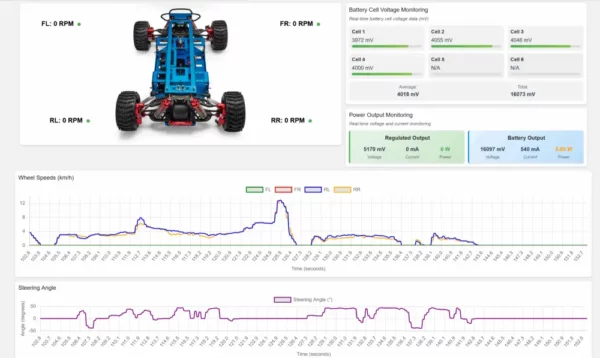
Case Study: How Influx’s Use of the CanEduDev Rover Platform is Accelerating Automotive Development and Demo Capabilities
Case Study: How Influx’s Use of the CanEduDev Rover Platform is Accelerating Automotive Development and Demo Capabilities Executive Summary Influx Technology is leveraging the CanEduDev Rover platform to enhance its demonstration and testing capabilities, addressing
CAN-ROS Integration: What Auto & Industry Need to Know
As someone working in automotive and industrial automation, you’ve likely faced this dilemma: How do we leverage modern robotics frameworks without compromising the real-time guarantees our systems require? [Download the full paper here] At CanEduDev,
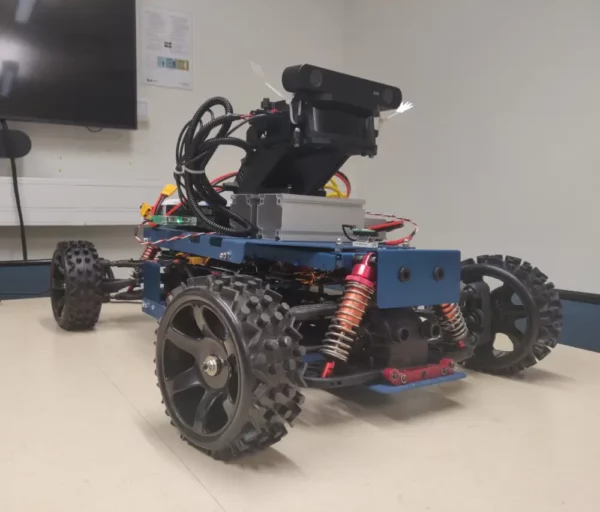
How LiU Formula Student Is Using the CanEduDev Rover to Drive Autonomous Innovation
At Linköping University, the Formula Student Driverless Team has taken on the challenge of building an advanced autonomous vehicle platform. To accelerate their development and testing processes, they’ve integrated the CanEduDev Rover into their workflow
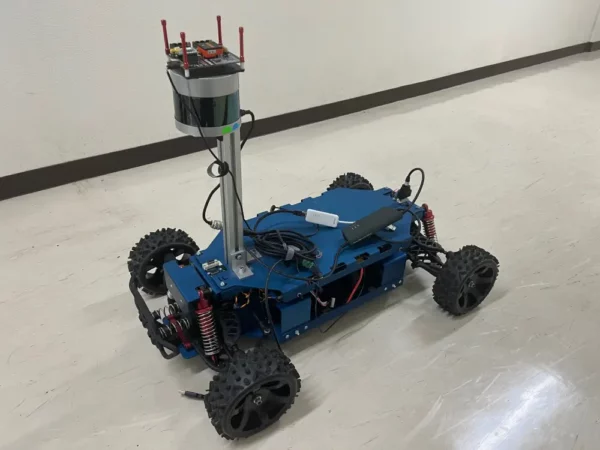
Bringing Autonomy to Life: Autoware Integration with the CanEduDev Rover
In Alex Carballo’s lab at Gifu University, cutting-edge research and hands-on robotics come together to create innovative solutions. In their latest project, headed by Tomoki Kuno, they showcase the power of Autoware Core/Universe in enabling
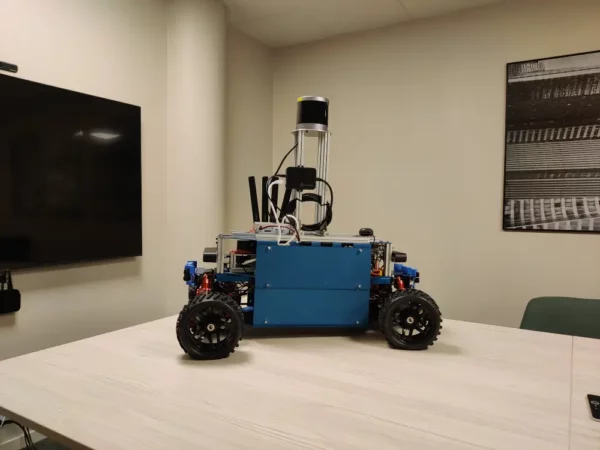
Unlocking the Future with CanEduDev Rover and ROS2 Integration
In an era where rapid advancements in automation and robotics are reshaping industries, real-time data acquisition, flexible control, and robust integration have become critical. To meet these demands, CanEduDev’s Rover offers a unique platform that
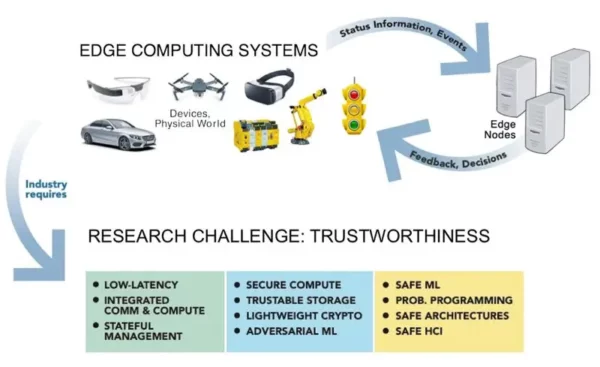
CanEduDev Partners with KTH and Telenor on Advanced Autonomous Driving Project
Project Summary The collaboration between CanEduDev, the Royal Institute of Technology (KTH), and Telenor represents a pioneering effort to push the boundaries of autonomous driving technology on a small scale. The project, titled “Autonomous Drive
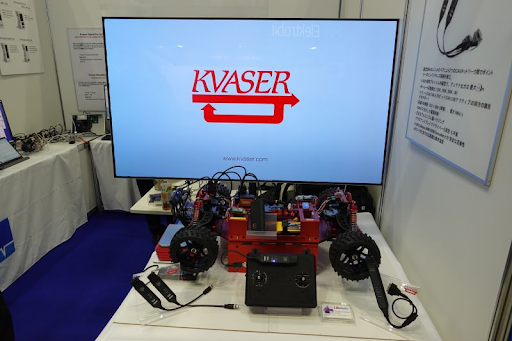
CanEduDev formally partners with Kvaser
As a newly appointed Technical Associate to Kvaser, CanEduDev is set to bring its Rover platform to the forefront of CAN technology demonstrations and education. This collaboration underscores our shared dedication to enhancing the practical
CanEduDev Rover: Progress Report on System Integration and Architecture
CanEduDev Rover: Technical Progress Update on System Integration We are excited to share a detailed update on the ongoing development of the CanEduDev Rover, a key project within our collaboration with Telenor, KTH, and the